SOURABH
PRASAD
I work where learning-based control meets real hardware: reinforcement learning for cross-embodiment generalization, multi-modal perception, and ROS2 software engineering — with the embedded and control experience to actually get robots running in the field.
Led product definition for an assistive feeding device, turning 50+ user interviews into a technical spec, system architecture and a 12-month roadmap.
Stood up early-stage manipulator simulations to test the feasibility of feeding motions — reachability and workspace coverage around a seated user.
Selected to advance to the Hatchery’s Go-To-Market phase.
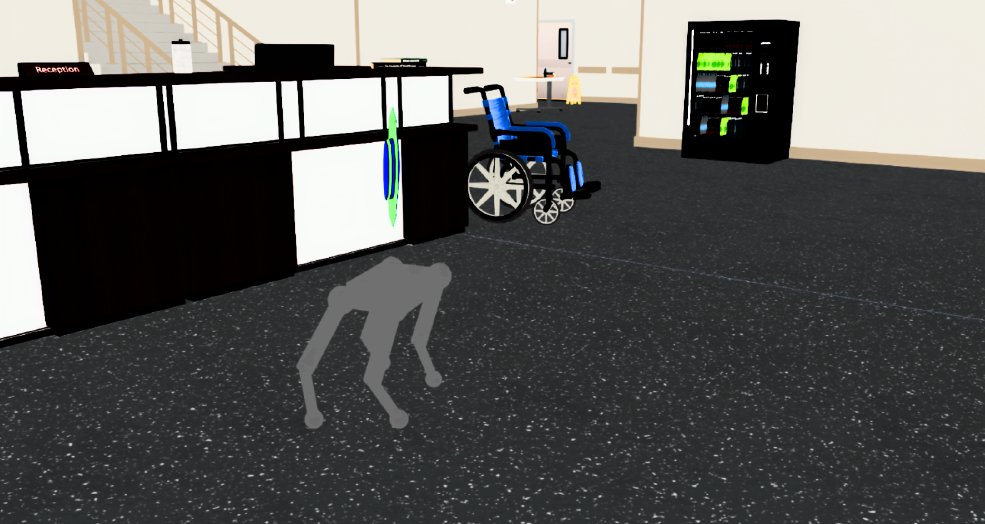
Paired a foundation-model visual planner (NoMaD) with a cross-embodied locomotion controller trained via PPO in NVIDIA Isaac Sim.
Morphology and domain randomization gave zero-shot transfer to unseen commercial-robot morphologies — 71–100% success across 4 terrain types.
Two years of graduate work in robotics and AI — control, perception and motion planning — ending in the cross-embodiment navigation research at NODE_05.
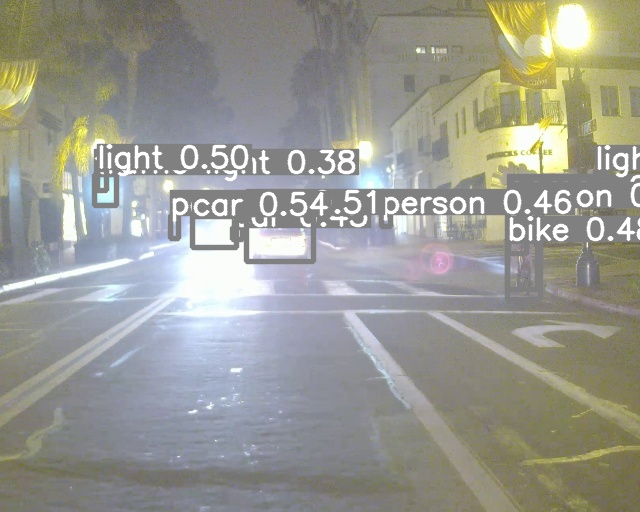
A late-fusion RGB + thermal pipeline using fine-tuned YOLOv5 and a custom MLP rescoring network, improving pedestrian-detection average precision by 28% in low light.
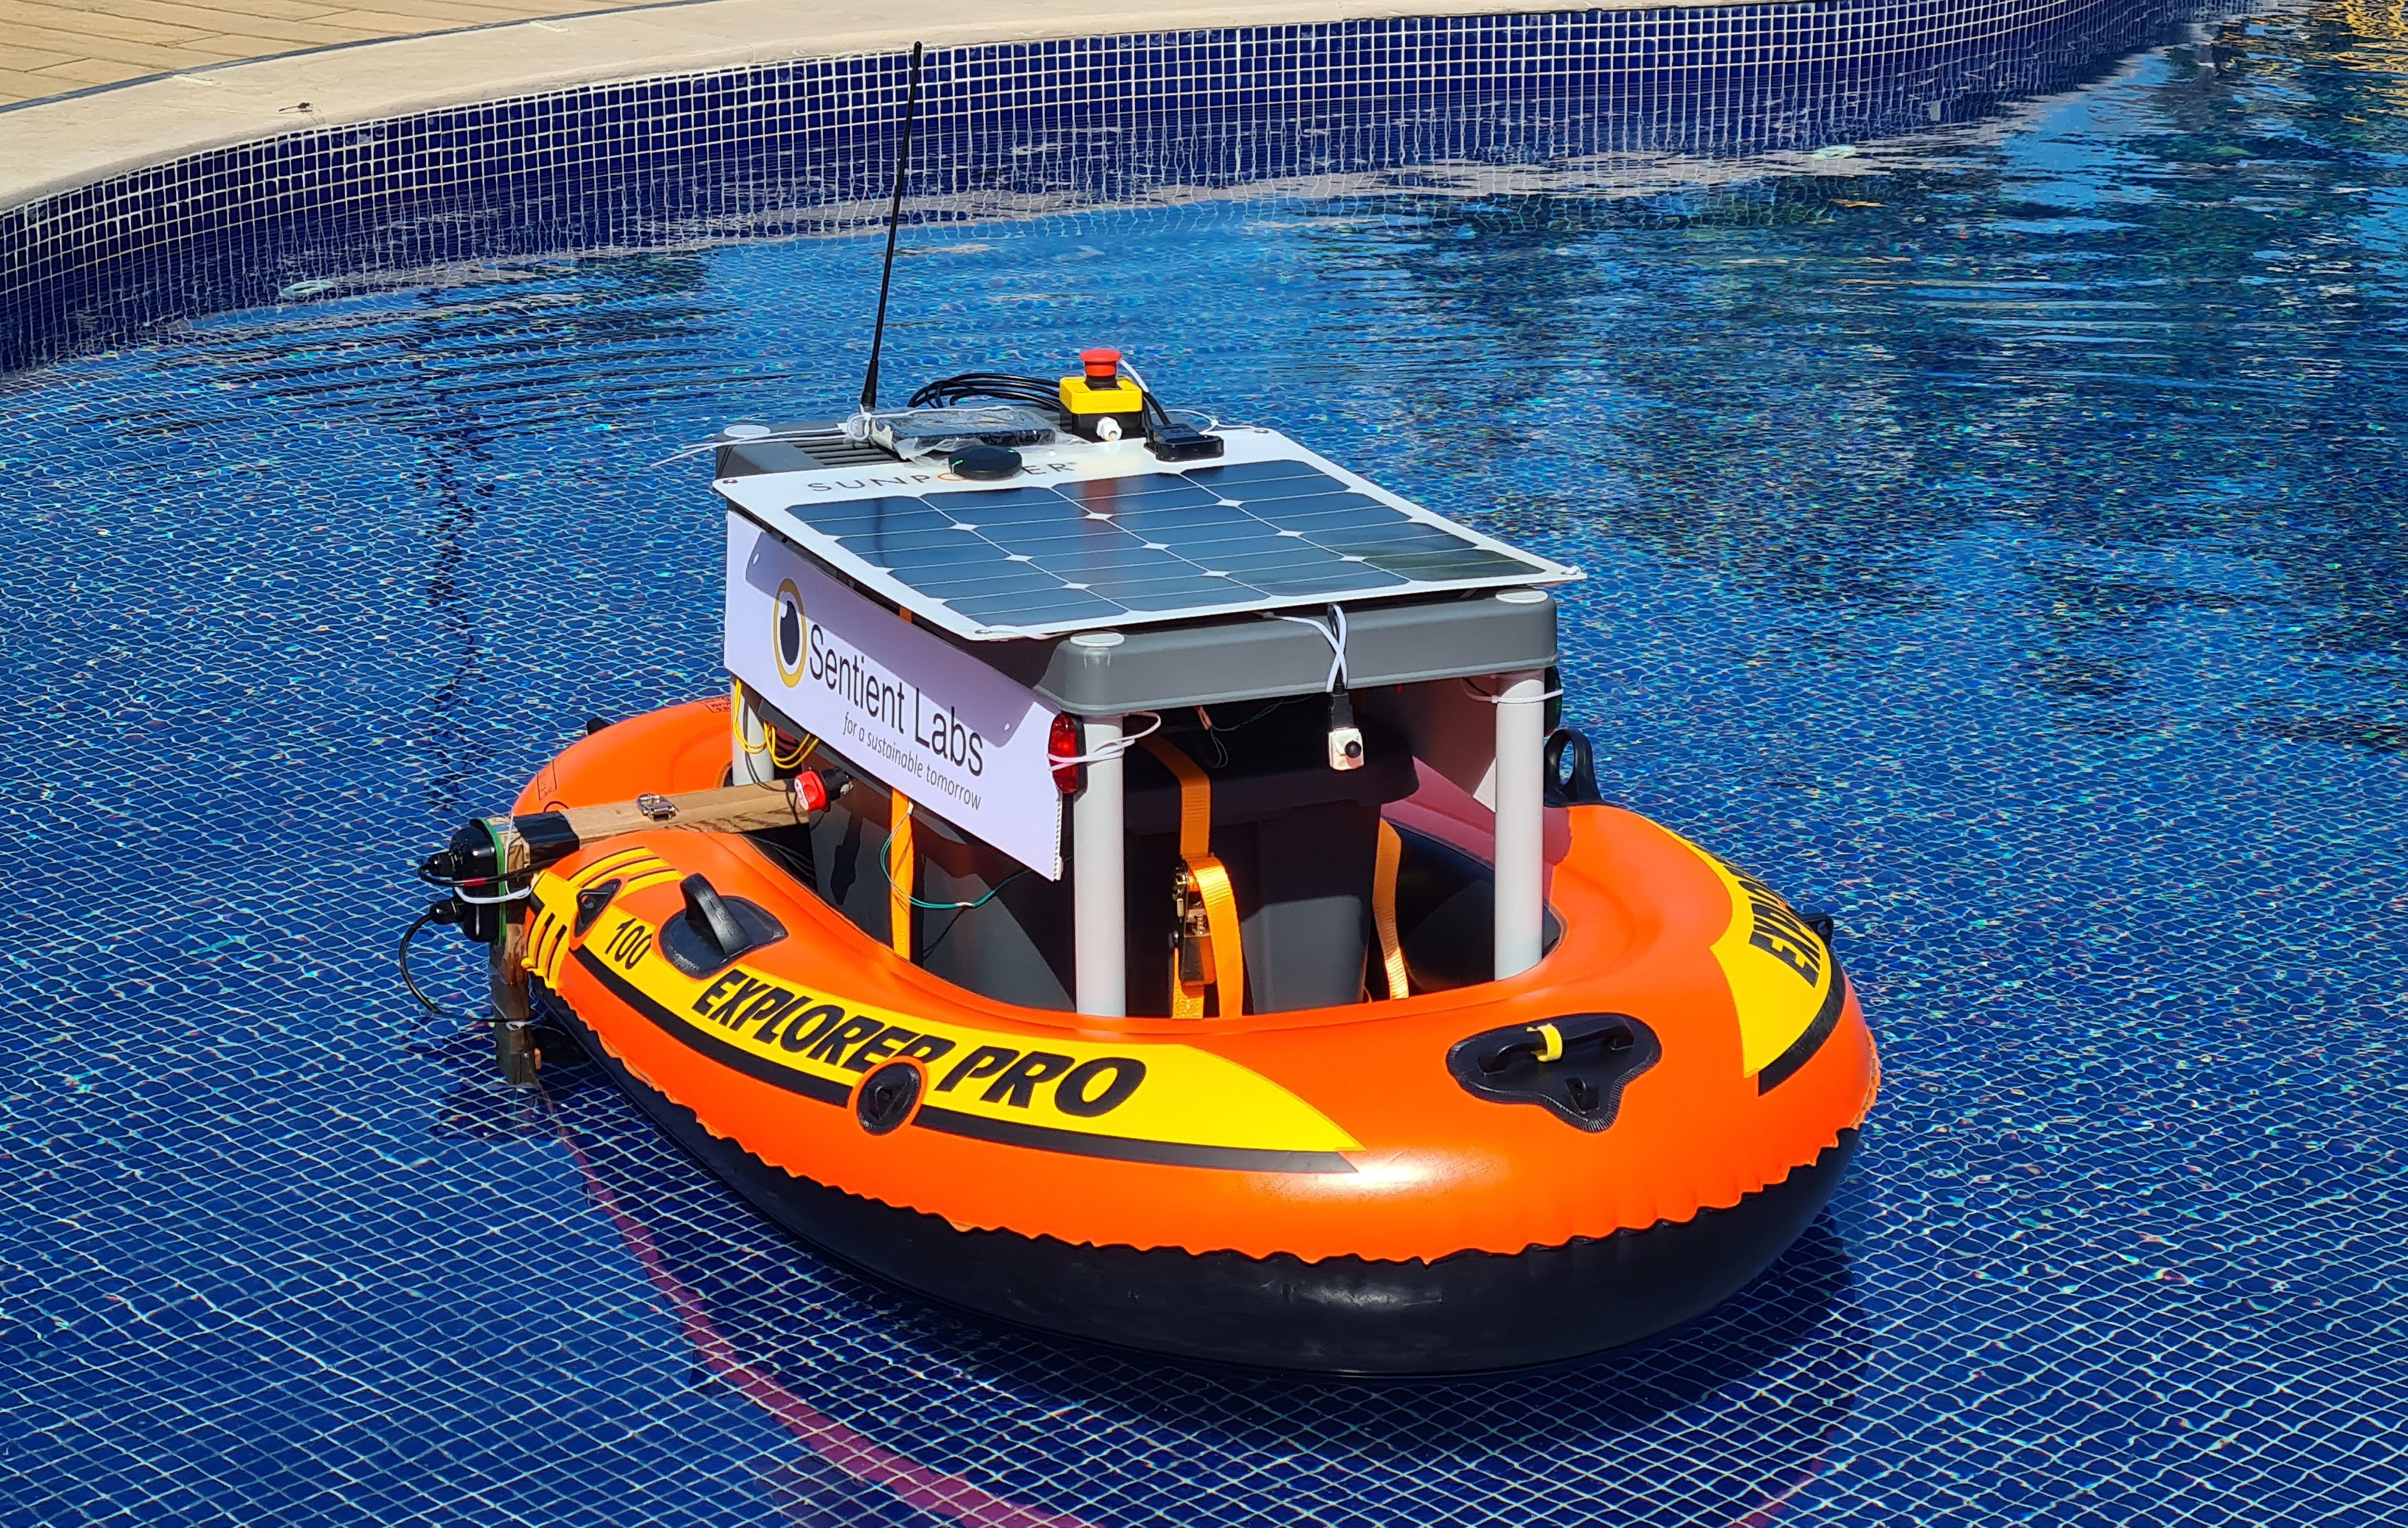
Multi-channel, fault-tolerant teleoperation stack for a USV — MAVROS/MAVLink bridging ROS commands to onboard ArduPilot over layered MQTT, P2P-VPN and redundant radio.
Low-latency multi-camera streaming (<200 ms end-to-end) on GStreamer + AWS.
Embedded control stack for a custom grasping manipulator: stepper control and kinematics on ROS2/Micro-ROS with MoveIt2 planning — 80% autonomous grasp success.
Containerized the full stack with Docker for one-command deployment.
Four-year mechatronics degree with a robotics and automation specialization — where the embedded and control work started.